Top 1% know-how from a working engineer
From C to motor control. A step-by-step guide to becoming an embedded developer.
Embedded roadmap
20 subjects and 182 topics in the order they build on each other.
- 01
- 02
- 03
- 04
YouTube videos
Videos from a channel with 26.4K subscribers, grouped by series in viewing order.

Motors
From DC motors to BLDC, EV traction motors, and stepper, servo and induction motors. Watched in order, it goes from why a motor turns to how it is controlled.
Communication buses
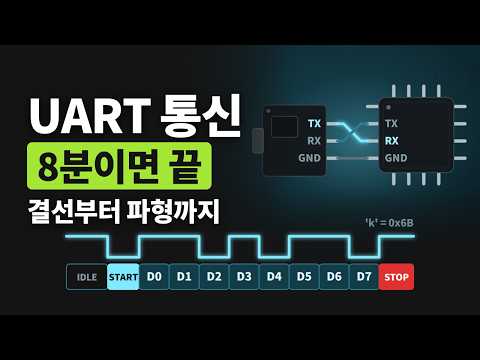
Starting with UART, SPI and I2C, then CAN, LIN, UDS and automotive Ethernet. The order climbs from chip-to-chip links to in-vehicle networks.

Circuits and hardware
From resistors, capacitors and inductors to PCBs, MCUs, power conversion and inverters. It starts with one part and widens to power circuits.

How products work
Drones, humanoids, robot vacuums, the Tesla Roadster. Finished products taken apart to see how circuit, firmware and control fit together in one device.
Notes
182 short notes, one per roadmap topic. 12 are in English so far.
Pointers
A variable that holds an address. Reading and writing a specific address is all register control is.
C LanguageBit operations
Clear with AND, set with OR, toggle with XOR, move with shifts.
C Languagevolatile, const, static
volatile blocks optimization, const fixes a value, static changes scope and lifetime.
MCU FirmwareKoreanGPIO
Input and output, push-pull and open-drain, internal pull-ups, at register level.
MCU FirmwareKoreanInterrupts and the NVIC
Priorities, why handlers stay short, and shared variables.
Communication ProtocolsKoreanI2C
Many chips on two wires. Addresses, ACK and choosing pull-up resistors.
Labs
Simulations where you change a value, run it and see the principle.
ADC Sampling and Resolution Simulation
Watch a smooth analog voltage turn into a staircase of numbers as it passes through an ADC. See how coarse the steps get with fewer bits, and why slow sampling makes a signal look like a different frequency.
3DInterrupts and Priority Simulation
Watch where the CPU jumps when an interrupt arrives in the middle of the main loop, and when it comes back. Try priority and preemption, long handlers, critical sections, and the endless re-entry you get when a flag is never cleared.
3DSPI
One bit per clock, with master and slave exchanging data at the same instant. Chip select, the four modes, and how a mode mismatch shifts the value you read.
3DI2C Bus
Put two sensors on one pair of wires and call them by address. Start condition, 7-bit address, ACK and NACK, and what happens without pull-up resistors, step by step.
3DPMSM and Field-Oriented Control
See the current vector made by three phase currents and the rotor's d and q axes in 3D, and how iq, id and encoder angle error affect torque.
3DBLDC Six-Step Commutation
Watch six switch combinations, chosen by the Hall sensors, pull the rotor around one step at a time.
Free ebooks
Core topics, each written up at book length.
Serial Communication, All at Once
From UART to CAN and RS-485. How many wires each bus uses, what its waveform looks like, and when to choose which.
Free PDFKoreanSensors, All at Once
How a physical quantity becomes a number. How sensors turn temperature, acceleration, magnetic field, distance and current into data, and how to connect them to an MCU.
Free PDFKoreanIntroduction to BLDC Motor Control
From six-step to FOC. From electromagnetic basics to designing a three-phase inverter and spinning a BLDC motor with an STM32.
Courses
Once you have seen the principle, the next step is to build it yourself.