Open · Fast CampusTaught in Korean
All-in-One Project for Robotics & Embedded Development
One balancing robot covers C, firmware, circuits, mechanics, an app and a portfolio.
- 10parts
- 165lessons
- 30hours, approx.
The development order the course follows
 01
Requirements and design
Decide what to build, then prepare the HSI, the software architecture and the Git repository.
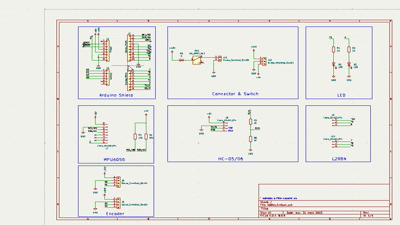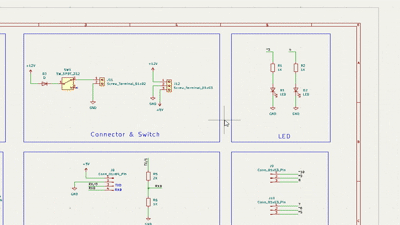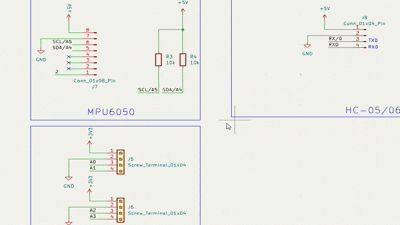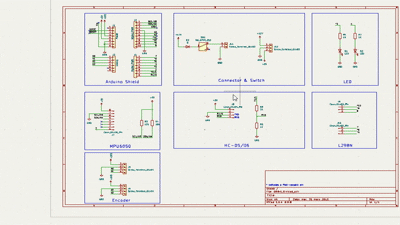 02
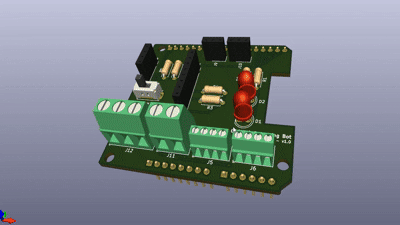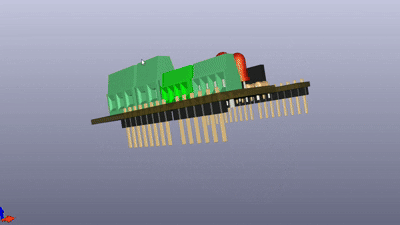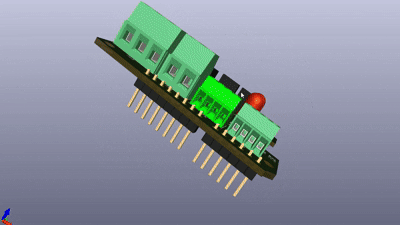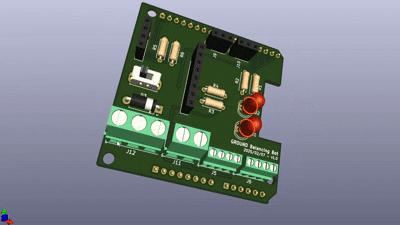
Circuit and PCB
Draw the schematic in KiCad and lay out a shield PCB made for the robot.
 03
PCB checks and ordering
Pass DRC, inspect the 3D view, then export Gerbers and order.
 04
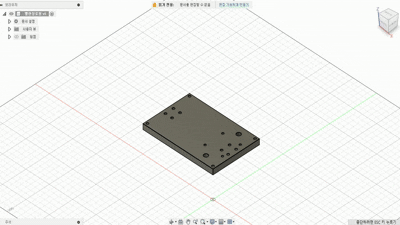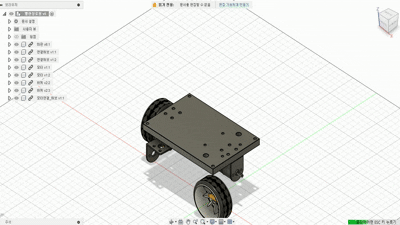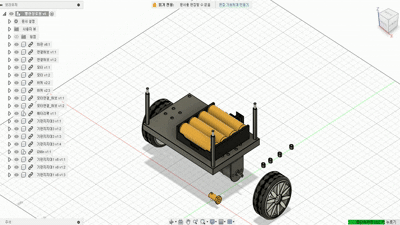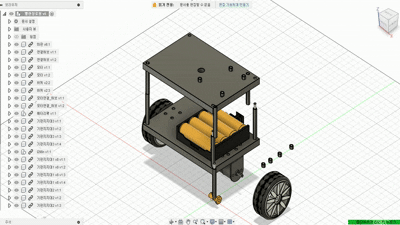
Mechanical design
Model the chassis and motor mounts in Fusion 360 and 3D-print them.
 05
Firmware and app
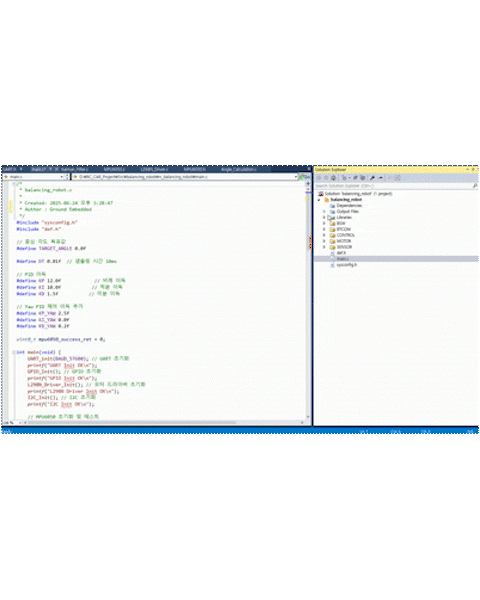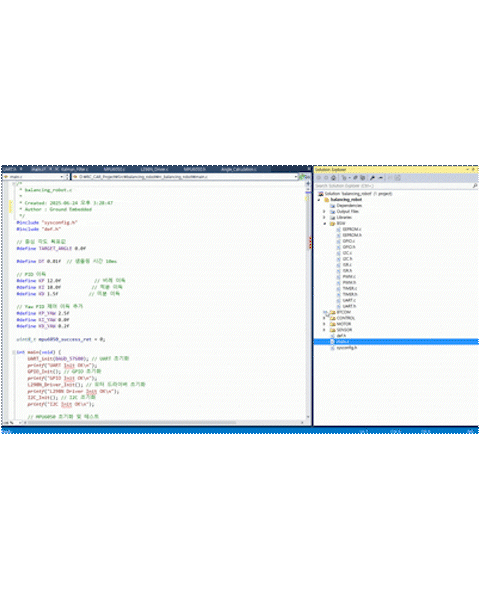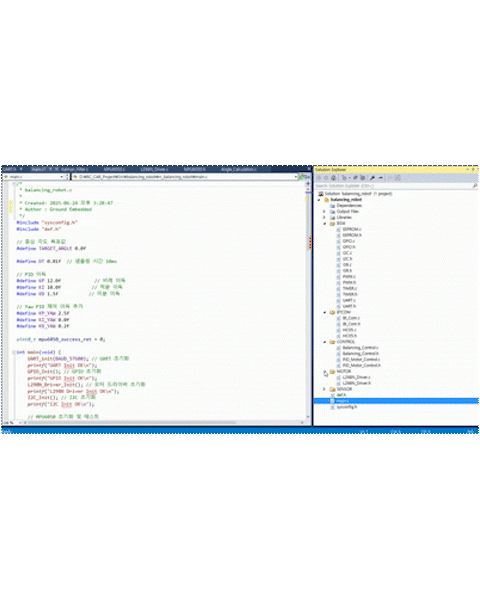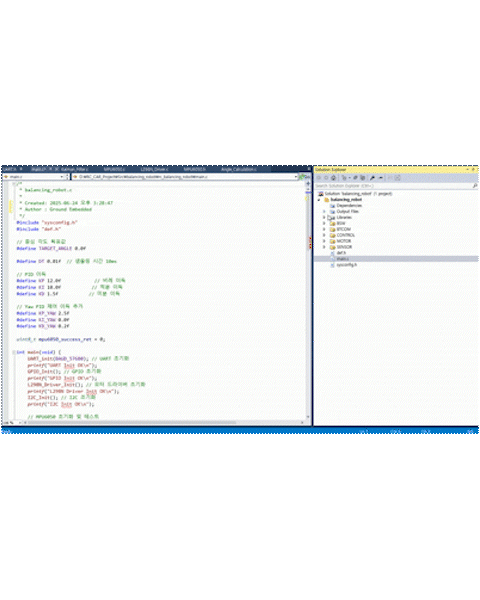
Handle the MPU6050, HC-05 and motors in a BSW/ASW structure and build an Android app.
 06
Integration test
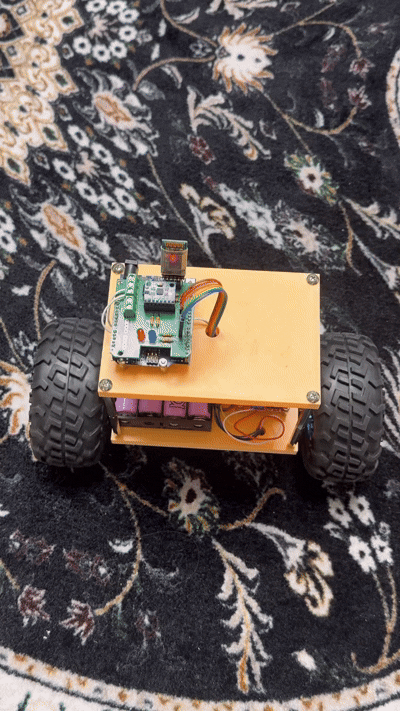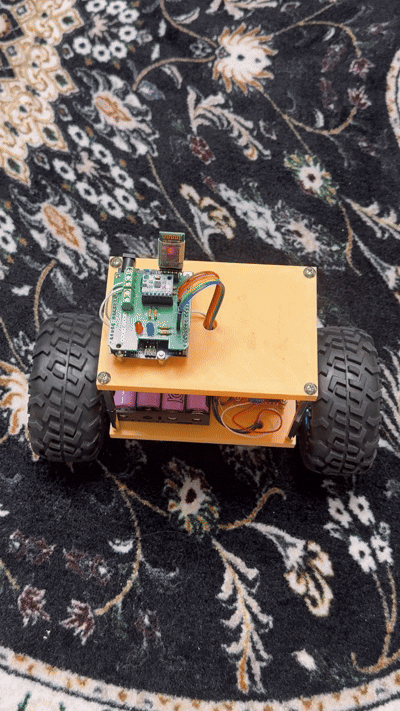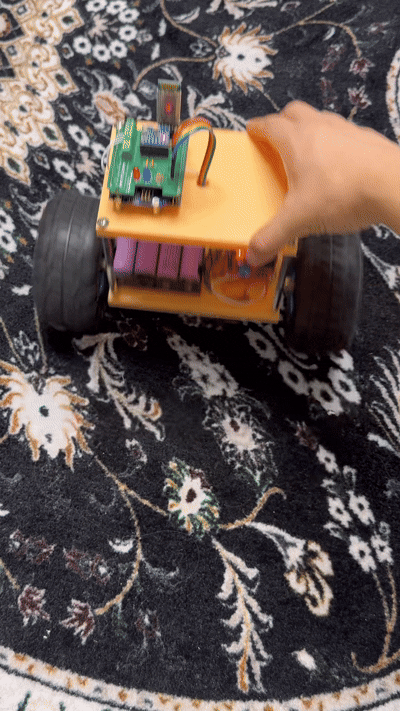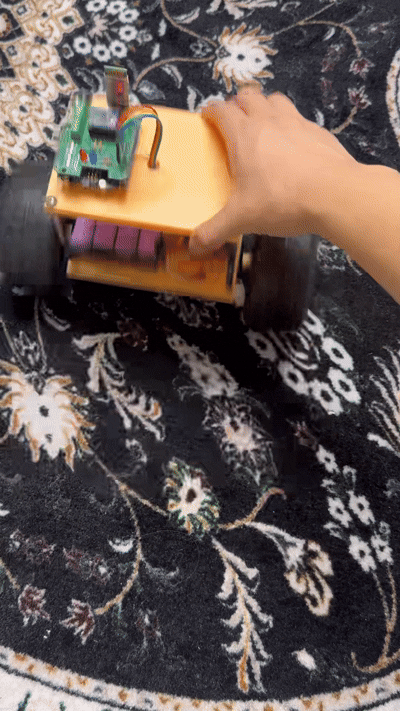
Tune the Kalman filter and PID until the robot stands on its own.