Communication buses 13 videos
Starting with UART, SPI and I2C, then CAN, LIN, UDS and automotive Ethernet. The order climbs from chip-to-chip links to in-vehicle networks.
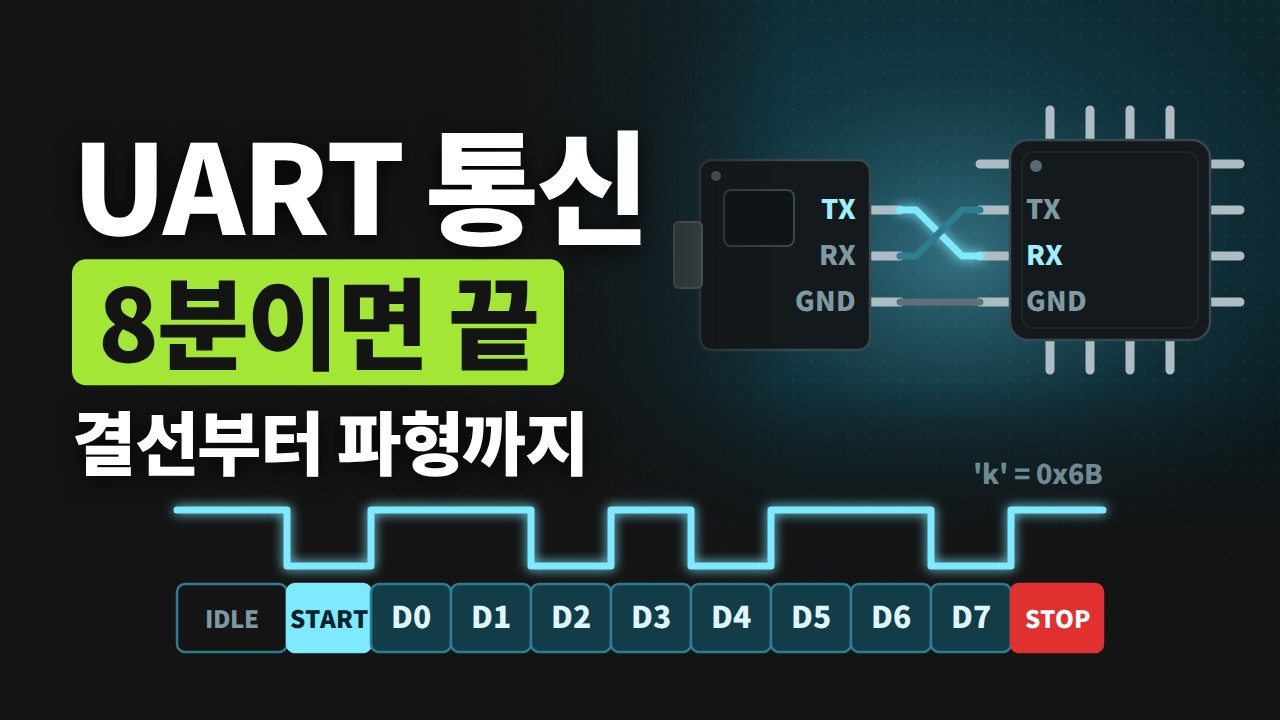
01UART, fully explained | Essential for EE students and embedded developers
The videos are narrated in Korean. Turn on YouTube captions and choose auto-translate to follow in English.
 8:1301UART, fully explained | Essential for EE students and embedded developers2.6K views
 4:4002SPI, fully explained | Essential for EE students and embedded developers2.7K views
 9:5003I2C, fully explained | With an Arduino MPU6050 exercise7.8K views
 22:4404UART, SPI and I2C compilation | The first three buses you meet in embedded2.9K views
 10:1505CAN, fully explained: the bus you have to know92K views
 10:1006LIN, fully explained: the bus you have to know30K views
 10:0307What happens when a warning light comes on? UDS diagnostics explained2.3K views
 30:0708In-vehicle networks in one video (CAN, LIN, UDS)27K views
 13:2409Automotive Ethernet in one video14K views
 7:3010Same CAN wires, so why CANopen? Until a robot arm picks up one box (SDO, PDO, SYNC, NMT, CiA 402)5.9K views
 36:4811Twelve serial buses in one video | UART, RS-485, I2C, SPI, CAN39K views
 4:4412OTA basics: essential viewing for embedded developers1.6K views
 13:3213OTA in depth: essential viewing for embedded developers3.2K views